FILTER // SMOOTHED · CLAMPED
Robotic Arm
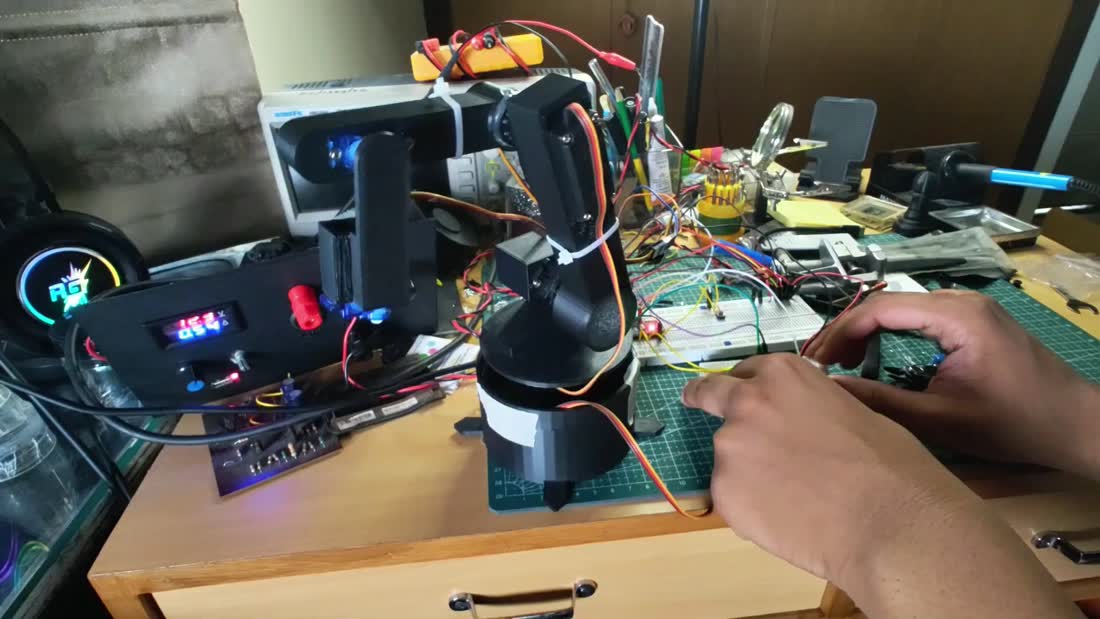
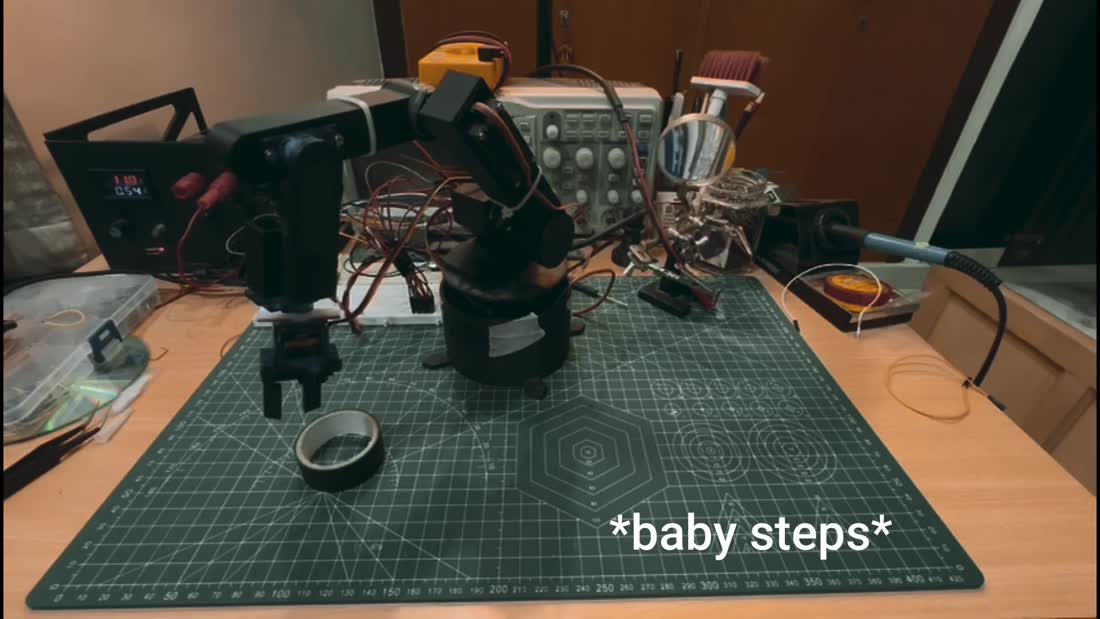
From the video “I built a Robotic Arm because my real one is lazy”. A 3D-printed, six-servo arm — gesture-controlled over ESP-NOW, then driven from an on-screen gamepad.


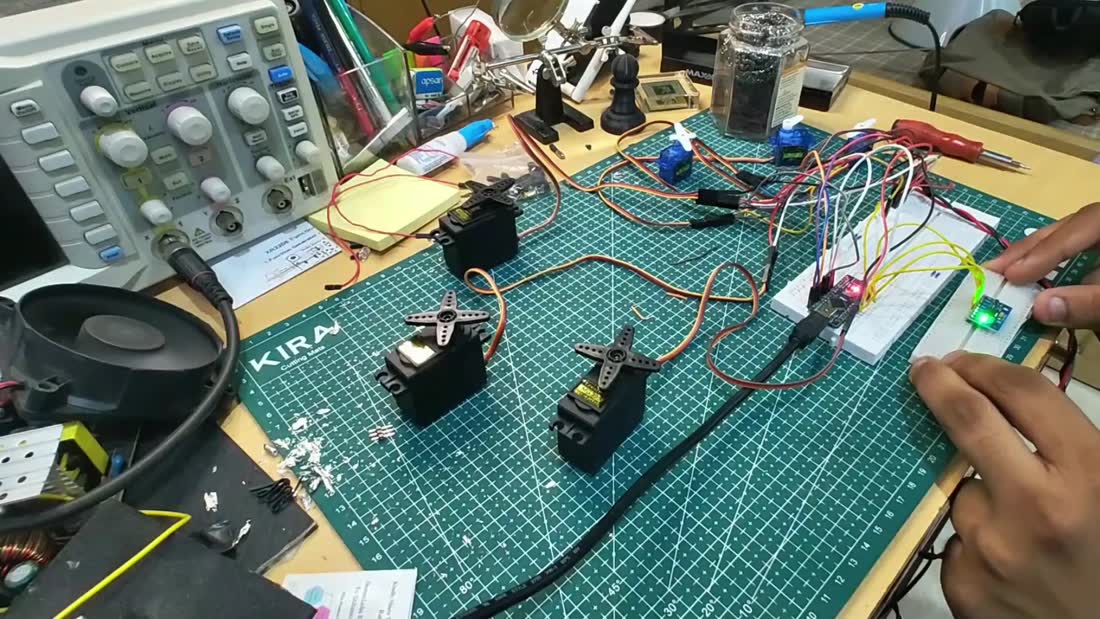
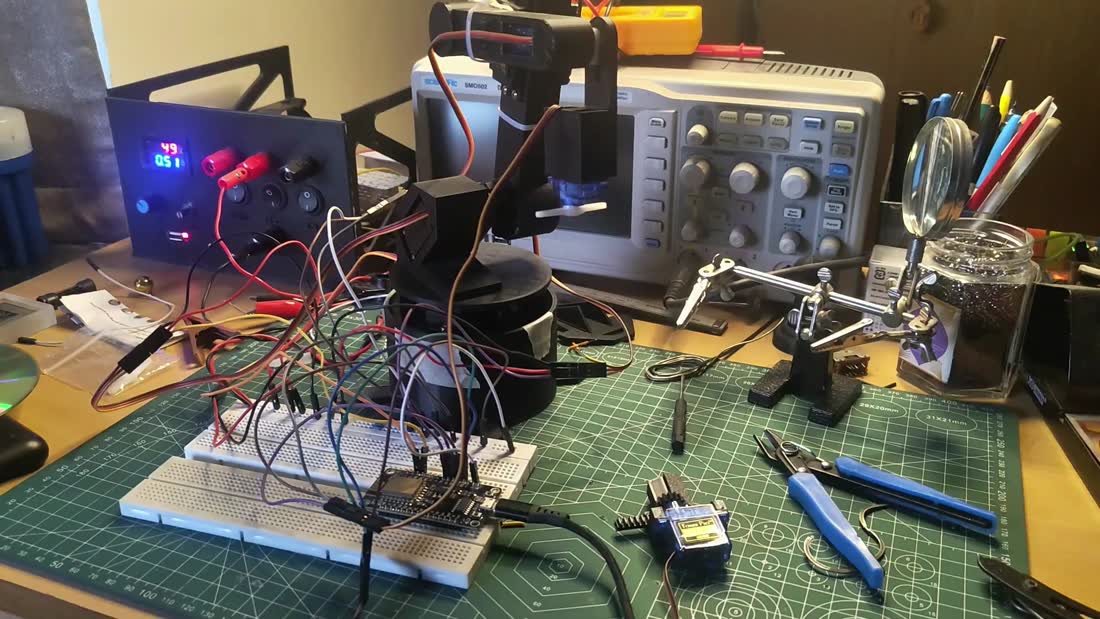
Joints: three MG996R metal-gear servos for the base, shoulder and elbow; three SG90 micro servos for wrist pitch, wrist roll and the gear-driven gripper.
Transmitter: an ESP32-C3 reads raw accelerometer and gyro data from an MPU-6050, converts it to roll and pitch, and sends it over ESP-NOW.
Receiver: a NodeMCU (ESP-12E) maps the angles onto six servo targets, then smooths and clamps each one before writing it. The servos run from a bench power supply with a common ground.
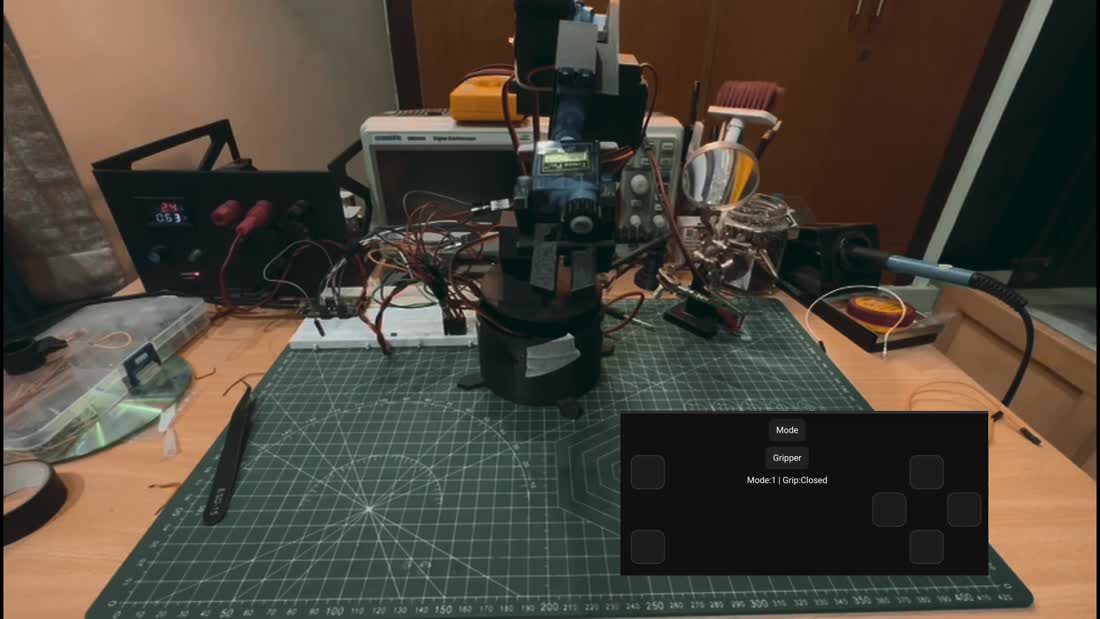
Control: gesture mode first, then an on-screen gamepad with a mode switch, a gripper toggle and directional pads.